Facility Name
External users: registration to be carried out only through I-STEM portal
Additional information about sample and analysis details should be filled in the pdf form provided in the I-STEM portal under “DOWNLOAD CSRF”
Internal users (IITB): registration to be carried out only through DRONA portal
Additional information about sample and analysis details should be filled in the pdf form provided here.
.
Category
- Services » Service
Booking Details
Facility Management Team and Location
Facility Features, Working Principle and Specifications
Facility Description
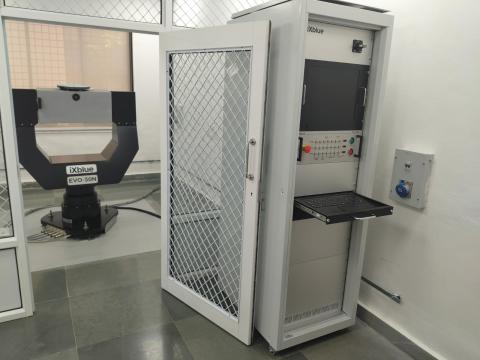
A three-axis angular motion simulator is a device used to physically reproduce the required pitch, yaw and roll angular rotations of the vehicle. This creates a feeling of the vehicle, which is in free rotational motion in a three-dimensional space. The ability to link a computer-based dynamic model of a particular system to physical motion provides information to the user on how the vehicle responds to control inputs without the need to construct expensive prototypes. Three-axis angular motion simulator can be used for high-accuracy angular positioning. This makes it useful for scanning and characterization tests of various sensors such as inertial gyros, accelerometers, inertial measurement unit, etc. Applications: Three-axis angular motion simulator is used by vehicle manufacturers and researchers to test guidance, navigation and control (GNC) hardware in coupling with/without the pilot interface. A three-axis angular motion simulator is used in Hardware-in-Loop Simulation during vehicle development to replicate realistic angular motion along with the target motion system. It interfaces with the vehicle’s guidance, navigation, and control loop to validate overall closed-loop performance.